Orbital Hardware Reference Design (Not Built)

BLADE-SPACE Governance Node

BLADE-SPACE = Beam-Layer Authority for Directed Engagements, Space-Edge Node

A reference design (design package and bill of materials; not built) for a radiation-tolerant, hot-redundant orbital governance node, intended to serve as the ethical decision-making authority for autonomous LEO platforms by determining in real time whether systems should EXECUTE, DELAY, ABORT, or enter CARA safe-mode based on multi-sensor trust consensus, beyond ground-loop latency. Radiation tolerance is a design target (30 krad TID allocation; not tested).

Preliminary Design Phase (TRL 2-3) · 15-Document Engineering Package · DOI 10.5281/zenodo.20183269

This is NOT a weapon. It is a governance layer, specified as a radiation-tolerant, hot-redundant, hardware-enforced ethical checkpoint between autonomous orbital platforms and authority-gated actions (propulsive maneuvers, payload firing, rendezvous-proximity operations). DoD Directive 3000.09 requires that autonomous and semi-autonomous weapon systems be designed to allow commanders and operators to exercise appropriate levels of human judgment over the use of force; this design adapts that human-judgment principle to spacecraft actions beyond ground-loop latency.

Launch Governance Simulator Zenodo Record Repository Evaluation Protocol Proposed SDK Interface
Type: Space-Edge Hardware Research Focus: Autonomous Orbital Governance · Radiation-Tolerant Edge Compute · Authority-Gated Decisions Status: Preliminary Design Phase (TRL 2-3) · 15-Document Engineering Package DOI: 10.5281/zenodo.20183269 Document ID: BLADE-SPACE-SRD-001 r1.0

Key Contributions

  • First reference design extending the AUTHREX authority-governance stack into the orbital domain (TRL 2-3 Preliminary Design Phase)
  • 9-stage governance pipeline (SATA → ADARA → IFF → HMAA → MAIVA → FLAME → CARA → BDA → EFFECTOR) specified in the reference design for radiation-tolerant compute (the browser simulation demonstrates a related seven-stage orbital authority pipeline, not this hardware pipeline)
  • Hot-redundant compute architecture: Microchip RTG4 FPGA (primary + backup) + Aitech S-A1760 Venus SBC (primary + backup) with a <200 ms failover target
  • Three-fault-tolerant payload/thruster firing path: two independent normally-open solid-state relays + pyrotechnic isolation
  • ECDSA-anchored audit chain: P-256 keypair in rad-tolerant TPM, hash continuity across reboots and brown-outs
  • ADARA multi-constellation GNSS cross-correlation for spoofing detection (primary + backup NovAtel OEM7600-RG receivers)
  • 30 krad TID design behind 3 mm Al equivalent shielding; LEO 400-1200 km, 5-year design life (7-year stretch)
  • 91-component BOM, $505,440 reference cost, 11.0 kg estimated mass (12.0 kg allocation), 134 W nominal / 193 W peak on 28V bus

Engineering Package: 15 engineering design documents in blade-space-repo.zip - System Requirements Document (25 traceable requirements), Requirements Traceability Matrix, FMEA (35 failure modes, 7 catastrophic), Hazard Analysis (10 hazards, 3 critical with three-fault-tolerant mitigations), V&V Plan (20-test campaign), Power / Mass / Thermal Budgets, 11 Interface Control Documents, Reliability Analysis, Radiation Analysis (30 krad TID, SEU/SEE), Assembly & Integration Plan, Configuration Management Plan. Published on Zenodo: DOI 10.5281/zenodo.20183269.
91
Components
134
Electrical Connections
9
Pipeline Stages
~$505K
Reference BOM
<300ms
Decision Latency (target)
11.0 kg
Mass (12.0 kg allocation)
30 krad
TID Tolerance (design target)
5 yr
LEO Design Life
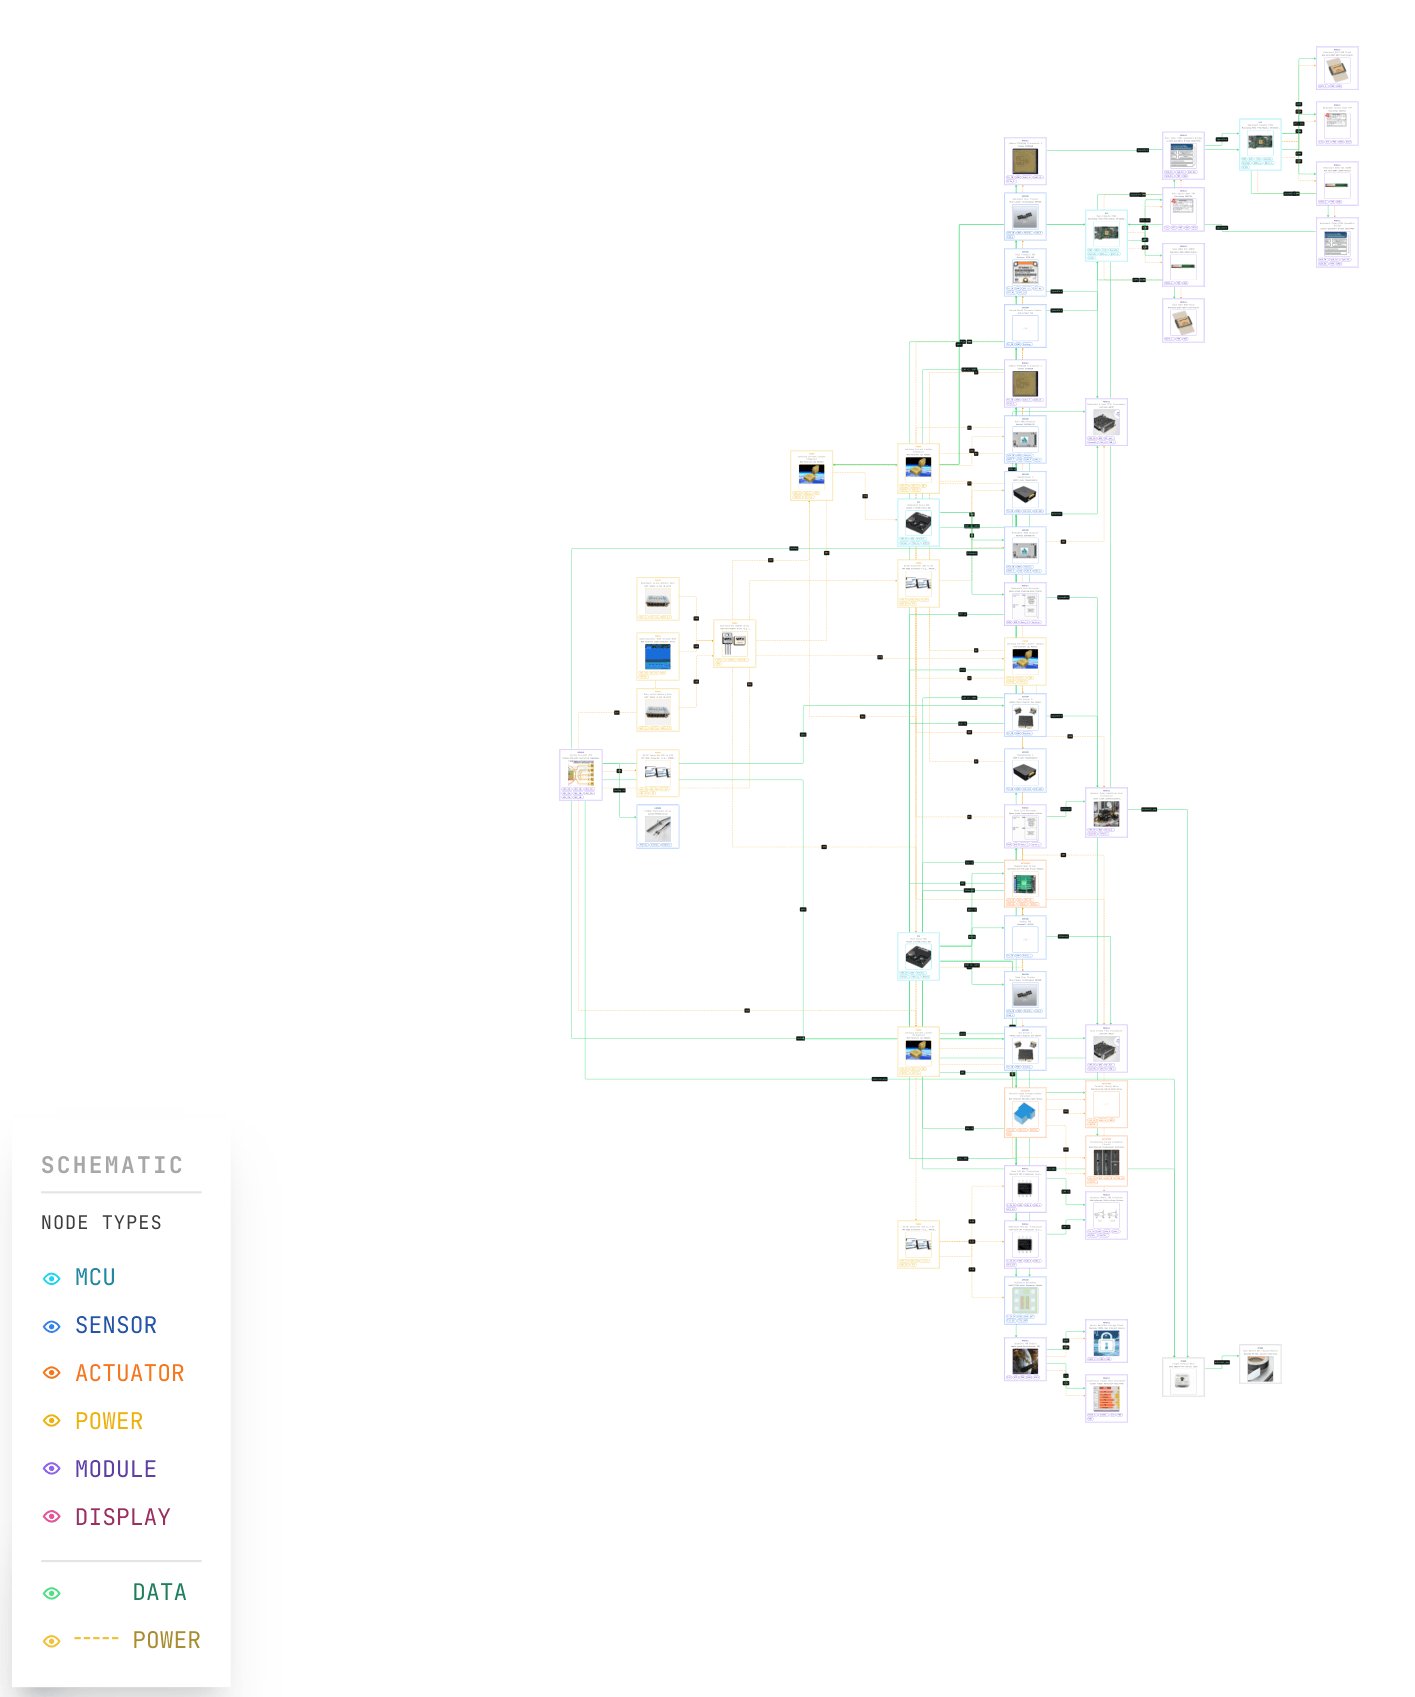
BLADE-SPACE Governance Node system schematic: 91-component node graph showing all subsystems (compute, sensors, communications, power, security) with 134 electrical connections, color-coded by node type (MCU, Sensor, Actuator, Power, Module, Display).
BLADE-SPACE Governance Node: reference design system schematic (not built) with 91 components and 134 electrical connections, color-coded by subsystem. All critical paths are specified as hot-redundant with SpaceWire bridge voting and Latching Current Limiter trip on SEU latch-up.

Why It Matters

Autonomous orbital platforms - rendezvous-proximity operations spacecraft, satellite servicing systems, distributed-spacecraft constellations, and orbital defense platforms - must execute authority-gated decisions (propulsive maneuvers, payload firing, RPO maneuvers) beyond ground-loop latency. A LEO platform may have minutes between command opportunities; some maneuvers must be authorized in seconds.

The space governance problem is structurally identical to the terrestrial autonomous-weapons governance problem (DoD Directive 3000.09 "appropriate levels of human judgment") but with three additional constraints: radiation environment (Single-Event Upsets corrupt computation deterministically), thermal cycling (-40 °C to +60 °C operating), and absolute repairability (no field maintenance after launch). The design premise of this work is that software-only governance cannot meet these constraints on its own.

The BLADE-SPACE Governance Node aligns directly with NASA SBIR 2026 Subtopic EXPAND.3.S26B (Autonomous Onboard Health Management for Small Spacecraft and Distributed Systems) and addresses the published Phase I expectation at TRL 3, with hot-redundant rad-tolerant compute, ECDSA-anchored audit chain, and three-fault-tolerant safety interlock on the payload/thruster firing path.

Research status: Design-specified and simulation-demonstrated (TRL 2-4). Not operationally deployed. All evaluation uses synthetic data. Standards alignment is self-assessed and is not an official compliance, certification, or endorsement determination.

Research Problem

Autonomous orbital platforms operate beyond ground-loop latency yet must execute authority-gated decisions in real time. The approaches identified in the standards and literature reviewed for this work either delegate every decision to ground (incompatible with constellation-scale autonomy) or accept software-only governance that is vulnerable to SEU corruption, brown-outs, or radiation-induced compute path failures.

The BLADE-SPACE platform addresses five orbital governance gaps:

No rad-tolerant hardware governance layer for autonomous orbital authority decisions identified in the standards and literature reviewed for this work
GNSS spoofing in orbit is harder to detect than on ground (multi-constellation correlation required)
Single-string compute can fail on SEU; this design adopts hot redundancy with a <200 ms failover target
Audit chain must survive brown-outs, reboots, and failover events with cryptographic hash continuity
Payload/thruster firing requires three-fault tolerance against unintended actuation (per SR-401)

This reference design is intended to show, at design and simulation level only, that the AUTHREX authority-governance stack can be carried from defense (BLADE-EDGE) to the orbital domain by addressing radiation, thermal, and reliability constraints with hot-redundant rad-tolerant compute, ECDSA-anchored audit, and three-fault-tolerant safety interlocks (specified; not built or tested).

Orbital Governance Extension

The BLADE-SPACE extends the authority-governance stack from terrestrial defense (BLADE-EDGE) to the orbital domain. The 9-stage pipeline is preserved; the difference is in the environmental envelope and the failure modes the hardware must tolerate.

Radiation-Tolerant Compute Path

Microchip RTG4 FPGA (part-level TID 100 krad per datasheet, SEL immune) primary + backup with lockstep voting; Aitech S-A1760 Venus SBC primary + backup with Latching Current Limiter trip on SEU latch-up; SEU monitor IP + scrubber re-loads bitstream on detected upset. System-level TID allocation is 30 krad after 3 mm Al equivalent shielding margin.

Three-Fault-Tolerant Firing Path

Payload/thruster firing line gated through two independent normally-open solid-state relays (path A and path B) that must both close to permit firing, plus pyrotechnic isolation circuit with hardwired safe-arm plug during ground handling (per SR-004, SR-401)

ECDSA-Anchored Audit Chain

P-256 keypair anchored in rad-tolerant TPM signs every audit-chain entry; hash continuity maintained across reboots, brown-outs, and failover events (SR-008); ECDSA signature throughput ≥ 100/second (SR-105)

CARA Safe-Mode Auto-Entry

On ABORT verdict, system enters automatic magnetorquer detumble + sun-pointing safe-mode (SR-007). Backup IMU (Honeywell HG1700) provides ≤ 30 min dead-reckoning if GNSS lock lost; star-tracker correction observation update

The reference design is intended to show, at design and simulation level only, that AUTHREX governance is domain-agnostic: the same 9-stage pipeline specified for ground-based directed-energy engagement in the BLADE-EDGE reference design is specified here for propulsive maneuvers and payload firing, with environmental tolerances scaled to the orbital regime.

System Overview

In the reference design, BLADE-SPACE receives data from its dual-sourced attitude and navigation sensors (star trackers, GNSS receivers, tactical and backup IMUs, sun sensors and magnetometers) and its health sensors (radiation dosimeter, thermistor array and vacuum pressure sensor), processes it through a 9-stage governance pipeline specified for hot-redundant rad-tolerant compute (Microchip RTG4 FPGA and Aitech S-A1760 Venus SBC, each primary and backup), and outputs one of four decisions for an authority-gated action: EXECUTE, DELAY, ABORT, or CARA safe-mode. The design has not been built.

9-stage Governance Pipeline

In the design, every authority-gated action (propulsive maneuver, payload firing, rendezvous-proximity operation) passes through nine sequential stages, with an end-to-end latency target of 300 ms or less (V&V test T-008). Each stage can independently trigger an ABORT, preventing downstream execution.

Stage 1: SATA: Sensor Trust Attestation

Specified to compute a trust scalar τ by Dempster-Shafer fusion over the star tracker, GNSS, IMU, sun sensor and magnetometer trust channels, cross-checking each sensor against the others.

Stage 2: ADARA: Adversarial Deception-Aware Risk Assessment

Specified as multi-constellation GNSS spoofing detection (GPS, Galileo and GLONASS cross-check across the primary and backup NovAtel OEM7600-RG receivers) and telemetry anomaly pattern matching.

Stage 3: IFF (ground-station command authentication)

In BLADE-SPACE this stage is specified as ground-station command authentication: ECDSA P-256 verification of CCSDS authenticated telecommand frames before authority confirmation.

Stage 4: HMAA: Human-Machine Authority Architecture

Specified to derive trust-proportional authority over effector commands (thruster firing, magnetorquer torque, reaction wheels, payload activation), stepping down from propulsive-maneuver authority to reaction-wheel-only operation, attitude hold, and safe-mode as trust falls.

Stage 5: MAIVA: Multi-Agent Integrity Verification

Specified as cross-string consensus between the main and redundant compute paths, with SpaceWire bridge voting and a divergence-detection target under 200 ms. The consensus is intended to bound the influence of a faulty or compromised string; this is not asserted as a guarantee while the MAIVA CriticalSafe invariant remains open.

Stage 6: FLAME: Flash War Latency Architecture

Specified to impose a mandatory deliberation window before propulsive maneuvers and payload firing (configurable hold period, default 5 s), so that a ground operator can confirm or veto when the link is available.

Stage 7: CARA: Control Authority Regulation

Specified safe-state enforcement on hardware fault or ABORT verdict: magnetorquer detumble and sun-pointing safe-mode, low-power operation and deselected effector commands (SR-007), with CCSDS event logging.

Stage 8: BDA (post-event trust revalidation)

Specified post-event trust revalidation and orbit-determination refresh after a maneuver completes, feeding back to SATA before the next authority-gated action.

Stage 9: EFFECTOR, Hardware Safety Interlock

Specified as a three-fault-tolerant hardware safety interlock: two independent normally-open solid-state relays (paths A and B) that must both close to permit firing, plus pyrotechnic isolation with a hardwired ARM/SAFE plug (SR-004, SR-401). The interlock is designed to close only when the full 9-stage pipeline confirms authority.

Final Decision = Pipeline Authority (HMAA authority level)

Gated actions: propulsive maneuvers, payload firing,
rendezvous-proximity operations

Output: EXECUTE | DELAY (FLAME hold) | ABORT | CARA SAFE-MODE

Authority Decision Model

In the design, BLADE-SPACE outputs one of four decisions based on pipeline authority. Instead of a binary go/no-go, the governance model provides a graduated response, with automatic CARA safe-mode entry on ABORT.

EXECUTE

Full pipeline authority confirmed. Both firing-path relays (paths A and B) close and the propulsive maneuver or payload firing is permitted.

DELAY (FLAME hold)

Ambiguous conditions detected by FLAME. The design holds the action for the configured deliberation window (default 5 s), re-queries sensors, re-runs ADARA, and re-checks MAIVA cross-string consensus.

ABORT

Trust collapse, deception detected, or cross-string consensus failure. The firing-path relays remain open and CARA safe-mode entry begins.

CARA SAFE-MODE

On a hardware fault, or after an ABORT verdict, the design enters automatic magnetorquer detumble and sun-pointing safe-mode (SR-007); the backup IMU (Honeywell HG1700) provides up to 30 minutes of dead-reckoning if GNSS lock is lost.

The payload and thruster firing line is specified with hardwired normally-open relays and is designed so that firing is not possible unless the pipeline confirms full authority through all nine stages. This is a design property of an unbuilt reference design, intended as hardware-enforced governance rather than software-only; it has not been tested.

Sensor-Anchored Trust Assessment (SATA)

The BLADE-SPACE design specifies SATA trust evaluation across its dual-sourced attitude and navigation sensors (star trackers, GNSS receivers, IMUs, sun sensors and magnetometers). Each feed is evaluated for signal integrity, noise floor, expected pattern consistency, and cross-correlation with the other sensors. The output is a single trust scalar τ ∈ [0,1].

Trust(s_i) = Dempster-Shafer fusion over the sensor trust channels.
Cross-sensor validation: star tracker + GNSS + IMU + sun sensor + magnetometer.
A GNSS fix that disagrees with the star tracker and IMU reduces τ.
ADARA cross-checks GNSS across constellations (GPS, Galileo, GLONASS) for spoofing.

In the orbital design, multi-constellation GNSS cross-correlation is coupled to the trust layer because GNSS spoofing in orbit is harder to detect than on the ground (see Research Problem above).

Hardware Architecture: Compute, Sensors, Communications & Security

The BLADE-SPACE reference design (not built) specifies rad-tolerant, hot-redundant space-grade hardware. All compute paths are specified as dual-string with SpaceWire bridge voting and a < 200 ms failover target. Sensors are independently dual-sourced (star tracker, GNSS, IMU, sun sensor, magnetometer) and cross-checked through the SATA sensor trust module and ADARA multi-constellation correlation.

Compute Subsystem (FPGA + SBC Hot Redundancy)

ComponentModelQtyRole
Main Compute FPGAMicrochip RTG4 (RT4G150)1Rad-tolerant programmable logic, primary pipeline
Backup Compute FPGAMicrochip RTG4 (RT4G150)1Hot standby with SpaceWire bridge voting
Main Space SBCAitech S-A1760 Venus1Rad-tolerant PowerPC, primary application processor
Redundant Space SBCAitech S-A1760 Venus1Hot standby; LCL trip + failover < 200 ms
DDR4 ECC SDRAMRad-hard DDR4 ECC Module1Compute memory with ECC scrubbing
QSPI NOR FlashRad-hard QSPI NOR Flash1FPGA bitstream + boot
Secure Boot TPMMicrochip CEC17121Boot-chain attestation, key isolation
SpaceWire TransceiversCobham UT200SpW4Compute-to-subsystem high-speed bus

Sensor Subsystem (AOCS + Navigation + Health)

ComponentModelQtyRole
Star Tracker (Main + Redundant)Blue Canyon Technologies NST1002≤ 30 arcsec 3σ attitude knowledge (SR-102)
GNSS Receiver (Main + Redundant)NovAtel OEM7600-RG2≤ 5 m 1σ dual-fix position; ADARA spoof detection
Tactical IMU (primary)Sensonor STIM-3001≤ 0.5 °/hr bias stability (SR-104)
Backup IMUHoneywell HG1700130-min dead-reckoning during GNSS lock loss
Sun SensorsAdcole Micro Digital2Coarse attitude for safe-mode sun pointing
MagnetometersZARM 3-axis2Magnetic field reference for magnetorquer control
Radiation DosimeterRadFET / PiN-diode1TID accumulation tracking
PT1000 Thermistor ArrayCustom array1Multi-point chassis + LRU temperature monitoring
Vacuum Pressure SensorSetra Model 7121Outgassing monitoring

Communications & Security

ComponentModelQtyRole
S-band TT&C TransceiverSyrlinks EWC27 (Main + Redundant)2Ground command/telemetry; hot redundant
Optical ISL TransceiverLaser Light Communications1High-rate inter-satellite link
CAN Bus TransceiversRad-hard (Main + Redundant)2Low-rate subsystem bus
Link EncryptorMicrochip ATECC608B + AES-256-GCM FPGA IP (Main + Redundant)2RF link confidentiality + integrity
Security TPM ModuleSpace-grade Rad-tolerant TPM1ECDSA P-256 anchor for audit chain (SR-003)
Secure Boot/Key FlashMacronix MX25L Rad-tolerant1Sealed key storage
Electronic Tamper Mesh ControllerCustom ASIC/FPGA1Tamper detection alarm

Power and Redundancy Architecture

The BLADE-SPACE design specifies a 28V regulated spacecraft bus with EMI filter, power sequencer, Latching Current Limiter array, and three VPT DC-DC converters producing 12 V, 5 V, and 3.3 V rails. Saft VES16 8S1P Li-Ion (135 Wh) provides eclipse + safe-mode ride-through; supercapacitor bank handles thruster-firing transients. 12 hot-redundant component pairs are specified to avoid single points of failure on critical paths; three open Critical Items List entries (DC-DC single-string failures) remain to be closed before Critical Design Review.

Hot-Redundant Pairs (12)

PrimaryBackupFailover Strategy
RTG4 FPGA primaryRTG4 FPGA backupSpaceWire bridge voting + bitstream scrubber
Aitech SBC primaryAitech SBC backupLCL trip + watchdog + auto-failover < 200 ms
Star Tracker mainStar Tracker redundantFailover on CAN heartbeat loss
NovAtel GNSS mainNovAtel GNSS redundantCross-validation + ADARA spoof detection
Sensonor STIM-300 IMUHoneywell HG1700 IMUCross-validate; 30-min HG1700 dead-reckoning
Sun Sensor 1Sun Sensor 2Independent attitude estimate
Magnetometer 1Magnetometer 2Independent magnetic field estimate
Syrlinks S-band TT&C mainSyrlinks S-band TT&C redundantIndependent RF chain
CAN transceiver mainCAN transceiver redundantBus A/Bus B redundancy
Link Encryptor mainLink Encryptor redundantIndependent crypto chain
Thruster SSR path AThruster SSR path BBoth must close for firing (SR-004)
Main Li-Ion batteryRedundant Li-Ion batteryBMS-controlled isolation

Power Architecture (28V Bus)

28V Spacecraft Bus
  → EMI Filter → Power Sequencer → LCL Array
    → VPT VSC50-28S12 (28→12 V, 88% eff) → SBC, Star Tracker, Thruster SSR
    → VPT VSC50-28S5 (28→5 V, 85% eff) → GNSS, IMUs, Comms, Encryptors
    → VPT VSC30-28S3R3 (28→3.3+1.2 V, 82% eff) → FPGA core, TPM, transceivers
  Saft VES16 8S1P (135 Wh) → Eclipse + safe-mode ride-through (19.6% DoD over 5 yr)
  Supercapacitor Bank → Thruster-firing transient absorption

Power Budget Summary

ModeLoad (W)Conv. Loss (W)Bus Draw (W)Current @ 28V
Nominal cruise112.522134.54.8 A
Pipeline active + comms TX145261716.1 A
Peak (comms TX + thruster prep)165281936.9 A
Eclipse safe-mode359441.6 A

PDR margin: 34% (193 W peak vs 250 W bus allocation). Battery cycle-life budget: ~30,000 cycles @ 20% DoD over 5 years - acceptable for design life.

Three-Layer Space-Grade Security

Layer 1: Physical

Space-grade aluminum chassis with 3 mm Al equivalent shielding (30 krad TID); ASTM E595 outgassing-compliant materials (TML < 1.0%, CVCM < 0.1%); hardwired safe-arm plug for pyrotechnic isolation during ground handling.

Layer 2: Electronic

Electronic tamper mesh controller raises alarm on probe attempt; LCL trip on SEU-induced latch-up < 1 ms; hardware watchdog forces reset on hang; SEU monitor IP + scrubber re-loads FPGA bitstream on detected upset.

Layer 3: Cryptographic

ECDSA P-256 keypair anchored in rad-tolerant TPM; signs every audit-chain entry with hash continuity across reboots/brown-outs/failover (SR-003, SR-008); ≥ 100 signatures/sec throughput (SR-105); dual link encryptors for RF chain redundancy.

Bill of Materials: $505,440 (Reference Cost)

91 components consolidated from the 124-component pre-cleanup design. Cost reflects rad-tolerant parts at single-unit / engineering-model pricing. Full parts manifest with manufacturer, MPN, and source URLs is in the engineering package.

SubsystemMass (kg)Allocation
Compute (RTG4 ×2, Aitech ×2, memory, bridge)1.9517.7%
Sensors (star tracker, GNSS ×2, IMU ×2, sun ×2, mag ×2, dosimeter, thermistor)2.3020.9%
Communications (Syrlinks, optical ISL, antennas, transceivers, encryptors)1.3011.8%
Power (Saft VES16, DC-DCs ×3, LCL, supercaps, EMI filter)1.6014.5%
Mechanical / Thermal (chassis, radiator, LHP ×2, CCHPs, MLI, indium pads)2.2020.0%
Actuation (SSRs, drivers, relays, servos)0.504.5%
Security (TPM, secure flash, tamper mesh, crypto coprocessor)0.252.3%
Connectors / harness / 12-layer PCB0.908.2%
Dry mass total11.00100%

Reference cost of $505,440 reflects rad-tolerant single-unit part pricing. The top three cost drivers are typically the optical ISL transceiver, the dual-redundant SBC + FPGA compute stack, and the dual-redundant TT&C transceivers. The engineering package contains the full per-line BOM CSV with manufacturers, MPNs, export-control classifications, and source URLs.

Physical & Environmental Specifications (Design Targets; Not Tested)

Form Factor6U+ SmallSat payload module
Mass (est. / target)11.0 kg / 12.0 kg
Power (nominal / peak)134 W / 193 W
Bus Voltage28V regulated
OrbitLEO 400-1200 km
Mission Life5 yr design / 7 yr stretch
Radiation TID30 krad behind 3 mm Al
Temperature (op / surv)-40 to +60 / -55 to +85 °C
VibrationGEVS-type random
Shock1000 g half-sine pyro
OutgassingTML < 1.0%, CVCM < 0.1%
ReliabilityR_system = 0.949 @ 5 yr

System Schematic

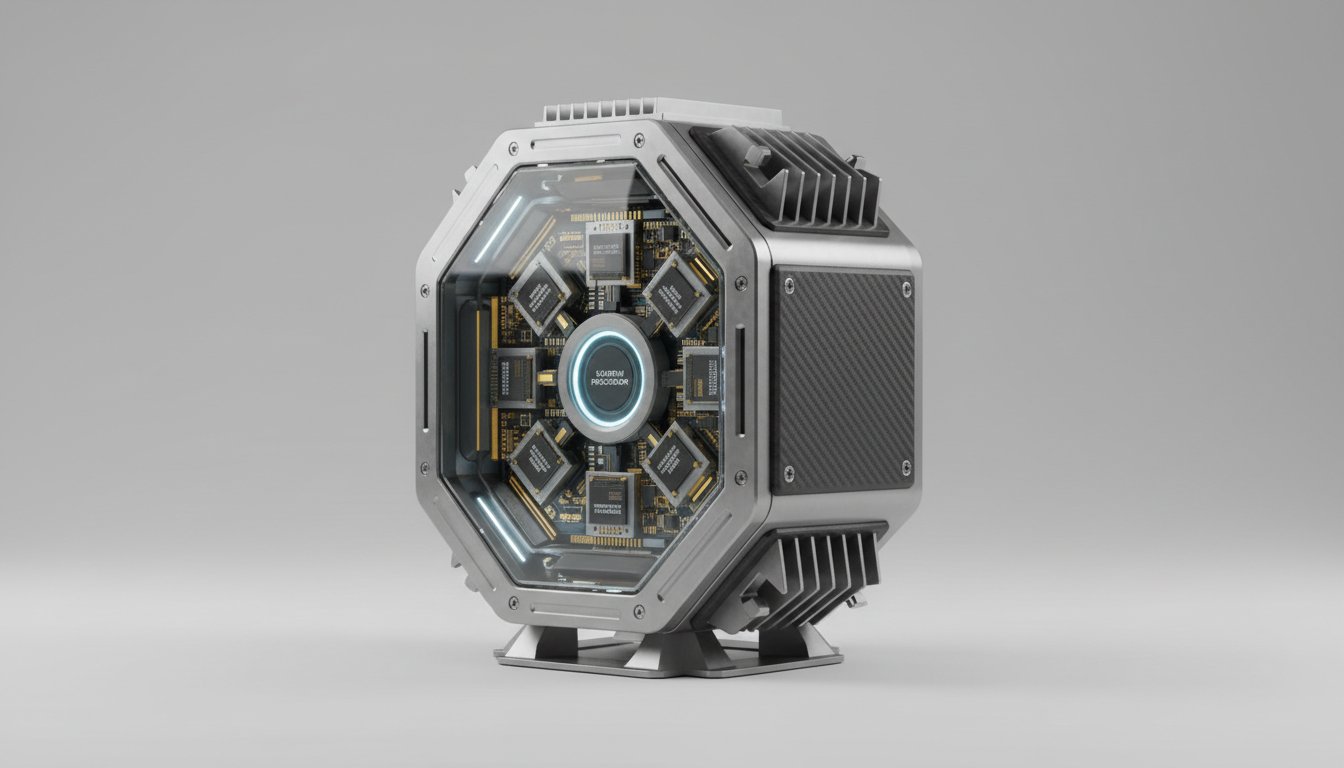
91 components, 134 electrical connections (53 power + 81 data), 117 mechanical connections. All critical paths are specified as hot-redundant with SpaceWire bridge voting and Latching Current Limiter trip on SEU latch-up. The image below is a reference render of the design; no hardware has been built.

BLADE-SPACE Governance Node 3D reference render (not built): octagonal space-grade aluminum chassis with visible internal PCBs through inspection window, multiple chips and modules, side-mounted heat sinks for radiative thermal management, mounted on hexagonal interface base.
View Full Schematic (PDF) ↓

Governance Simulation

The accompanying browser-based simulation (SAP-INT v3, a companion to the Space Authority Protocol manuscript) demonstrates a related seven-stage orbital authority pipeline (SATA → ADARA → MAIVA → FLAME → CARA → HMAA → ERAM) over six orbital scenarios, with fault injection for sensor loss, communications dropout, GPS spoofing and Byzantine nodes. It does not model the IFF, BDA or EFFECTOR stages or the RTG4 and Aitech SBC hardware of this reference design, and it uses synthetic parameters that are not calibrated against hardware.

Scenarios Available

  • Routine LEO conjunction avoidance
  • Direct-ascent ASAT threat response
  • Co-orbital terminal-phase approach
  • Multi-stakeholder debris engagement governance
  • Mega-constellation statistical governance
  • Cosmos 1408 retrospective
Launch BLADE-SPACE Simulator

Role in the Governance Stack

The BLADE-SPACE Governance Node is the orbital reference design (design package and bill of materials; not built) of the authority-governed autonomy framework. Its 9-stage pipeline specifies six of the seven governance architectures (SATA, ADARA, HMAA, MAIVA, FLAME, CARA) together with the IFF, BDA and EFFECTOR stages, as a Preliminary Design Phase reference architecture (TRL 2-3).

Related platforms: Rover Testbed (~$484) · UAV Platform (~$4,200) · BLADE-EDGE (defense, ~$139K) · BLADE-AV (automotive, ~$16K) · BLADE-MARITIME (maritime, ~$43K) · BLADE-INFRA (infrastructure, ~$12K) · BLADE-SPACE (orbital, ~$505K) · BLADE-CUAS (counter-UAS, ~$43.5K) · BLADE-AGENT-HSM (agentic AI, ~$199) · BLADE-SWARM (swarm autonomy, ~$1,333/node) · BLADE-INFRA-OT (IT/OT bridge governance, 1U fanless) · BLADE-FINANCE (financial-sector governance, ~$9K). Twelve hardware platforms in total: two physical research testbeds whose build is in progress (the rover and the UAV) and ten domain reference designs that have not been built; governance-stack portability is shown at design and simulation level only. Software companion: AUTHREX-SPACECYBER on AUTHREX Systems, a research application profile for onboard authority governance in orbital autonomy (single-author research, not deployed).

Design Metrics

91
Hardware components specified
134
Electrical connections (53 P + 81 D)
9
Governance pipeline stages
117
Mechanical connections defined
12
Hot-redundant component pairs
5
Sensor types cross-checked (SATA)

Verification & Validation Plan

The BLADE-SPACE V&V Plan specifies a 20-test verification campaign with pass/fail criteria, equipment lists, and method per test. The plan covers functional, performance, environmental, reliability, and safety requirements from the SRD.

Functional Tests

  • T-002: Payload-firing path safety interlock (FMEA F-009)
  • T-004: SBC primary-to-backup failover < 200 ms
  • T-005: ECDSA audit-chain hash continuity across reboots
  • T-007: GNSS spoofing via multi-constellation correlation
  • T-008: End-to-end 9-stage pipeline latency ≤ 300 ms

Performance Tests

  • T-006: Star tracker ≤ 30 arcsec 3σ / GNSS ≤ 5 m 1σ / IMU ≤ 0.5 °/hr
  • T-005: ECDSA throughput ≥ 100 signatures/sec

Environmental Tests

  • T-010: Operating temperature -40 to +60 °C
  • T-011: Survival temperature -55 to +85 °C
  • T-012: GEVS-type random vibration (3 axes)
  • T-013: 1000 g half-sine pyro shock (3 axes)
  • T-017: ASTM E595 outgassing
  • T-018: 30 krad TID

Risk Analysis

  • FMEA: 35 failure modes (7 catastrophic, 4 mitigated by redundancy)
  • Hazard Analysis: 10 hazards (3 critical with three-fault-tolerant mitigations)
  • Reliability: R_system = 0.949 at 5-year EOL with CIL closure
  • Radiation: 30 krad TID, per-part SEU/SEE classification

Three open Critical Items List entries (DC-DC single-string failures) require redundant converter addition before Critical Design Review. Vibration/TVAC/EMC qualification reports do not yet exist; V&V Plan specifies the campaign that will produce them.

Project Status: Preliminary Design Phase (TRL 2-3)

System Requirements Document (25 traceable SRs)
Requirements Traceability Matrix complete
91-component BOM with manufacturers + MPN + cost
134 electrical + 117 mechanical connections
Power budget: 134 W nominal, 193 W peak, 34% PDR margin
Mass budget: 11.0 kg / 12.0 kg allocation, 15% margin
Thermal analysis (radiator sizing, hot/cold-case)
FMEA (35 failure modes) + Hazard Analysis (10 hazards)
V&V Plan (20-test campaign specified)
3 fully specified ICDs (ICD-001/002/003)
ICD-004 through ICD-011: outline only, full pin-table pending
Thermal Math Model: node inputs specified, ESATAN-TMS pending
3 Critical Items List entries (DC-DC) require redundant converter add
Vibration / TVAC / EMC qualification reports: not yet executed
Honest assessment: This is a Preliminary Design Phase data package suitable for sponsor briefing, SBIR Phase I proposal supporting evidence, university capstone review, and early concept-review at a research program manager level. It is not yet flight-build documentation. The package explicitly identifies what is complete versus what is scoped for the next revision (Critical Design Review).

Engineering Package

Complete BLADE-SPACE Governance Node Preliminary Design Phase data package (15 engineering design documents). All files are original work by Burak Oktenli (independent researcher).

Complete Engineering Package (ZIP) - 15 documents + schematic SVG + parts CSV + JSON configs Interactive Governance Simulator (HTML, 269 KB) Full System Schematic (PDF, 3-page) Bill of Materials (CSV, 91 components)

Reproducible Research Artifacts

This project provides open artifacts for independent examination of the system design, component selection, and governance architecture.

System Design

Full schematic SVG (200 KB), CONFIG.json master configuration, ELECTRICAL_CONNECTIONS.json (134 connections), MECHANICAL_CONNECTIONS.json (117 attachments), all originals in the engineering package.

Bill of Materials

91-component PARTS.csv with manufacturer, MPN, description, export-control classification, cost, and source URL. Open the file in any spreadsheet tool; values reproduce the BOM table on this page.

V&V Protocol

VV_PLAN.md specifies the 20-test campaign with pass/fail criteria, equipment lists, and method per test. RTM.md links every SRD requirement to the test that verifies it.

Standards Alignment

DoDD 3000.09 (human-judgment principle for weapon systems, cited as context; this design is not a weapon), NASA SBIR EXPAND.3.S26B (spacecraft health management), GEVS vibration, ASTM E595 outgassing, NIST AI RMF.

Future Work · Path from TRL 2-3 to TRL 6+

The BLADE-SPACE Preliminary Design represents TRL 2-3. The roadmap below progresses through Critical Design Review (TRL 4), engineering-model fabrication (TRL 5), relevant-environment qualification (TRL 6), and operational infusion paths aligned with active U.S. Government programs. Each milestone is mapped to a specific funding vehicle or research initiative where the design is positioned to compete.

Phase 1 · 0-12 months: Documentation Hardening & SBIR Phase I

NASA SBIR Phase I (EXPAND.3.S26B)

Submit Phase I proposal to EXPAND.3.S26B - Autonomous Onboard Health Management for Small Spacecraft and Distributed Systems under the NASA SBIR/STTR Program Year 2026 BAA (released 17 April 2026, valid through 30 September 2027). The subtopic explicitly accepts terrestrial Earth-analog testbed demonstrations in Phase I, with Phase II advancing to flight-hardware validation and Phase III to operational infusion. BLADE-SPACE's 9-stage governance pipeline maps directly to the subtopic's call for "continuous on-board health management capabilities to detect anomalies, diagnose, isolate" faults - particularly the unknown-fault response requirement (up to 40% of failure modes go unidentified through Key Decision Point E).

CDR Closeout Documentation (TRL 4 entry)

Surface the 11 Interface Control Documents publicly (currently in ZIP only); add Requirements Traceability Matrix excerpt; declare NASA-STD-8739.8 software safety class (Class B target for firing-path firmware); add NASA-STD-8719.27 lithium-battery hazard analysis for Saft VES16; build ESATAN-TMS network thermal model with worst-hot / worst-cold orbital cases; publish AP9/AE9 or SPENVIS orbit-environment run output backing the 30 krad TID system-level allocation; add ITAR USML Category XV(e) export-control flag on documentation cover.

Phase 2 · 12-24 months: Engineering Model Build & Run-Time Assurance Integration

Custom 12-Layer PCB & Component Procurement

Class V QML / Class S parts procurement (12-18 month lead time for rad-hard T2080 and RTG4); flight-harness fabrication per NASA-STD-8739.4; ESD-controlled clean-room assembly per ISO 14644 Class 8. Engineering Model build with single-string electrical functional validation, then assembly to flight-hardware-equivalent (FHE) configuration with full hot-redundant pairs.

AFRL STARS Run-Time Assurance Integration

Integrate the AUTHREX 9-stage authority pipeline with AFRL's STARS (Safe Trusted Autonomy for Responsible Spacecraft) Run-Time Assurance framework (an AFRL Seedlings for Disruptive Capabilities program). This is a proposed research-alignment target; no affiliation, sponsorship, or funding relationship exists. Map the HMAA authority-graduation model onto the published STARL (Space Trusted Autonomy Readiness Levels) scale. The HMAA hardware-enforced authority gating is complementary to STARS RTA safety-filtering and provides the physical-layer enforcement that RTA assumes but does not implement.

Phase 3 · 24-36 months: Qualification Campaign & Relevant Environment (TRL 5-6)

Environmental Qualification (GEVS / MIL-STD-1540E)

Vibration to GSFC-STD-7000A GEVS qualification levels (14.1 g_rms random, 5 minutes/axis); 1000 g half-sine pyrotechnic shock per MIL-STD-810G Method 516.7 (MIL-STD-810G is superseded by MIL-STD-810H); TVAC across -55°C to +85°C at <10⁻⁵ Torr; ASTM E595 outgassing (TML <1.0%, CVCM <0.1%); MIL-STD-461G EMC against CE102 / CS101 / RE102 / RS103 / CS114; helium leak per pressurized vessel applicable items.

Heavy-Ion SEU Characterization

Single-event characterization at TAMU Cyclotron Institute or LBNL 88-Inch Cyclotron over LET 0.5-80 MeV·cm²/mg per JESD57. Measure FPGA configuration upset cross-section, SBC latch-up threshold, DDR4 ECC scrub margin. Validate the 100 krad part-level / 30 krad system-level TID allocation through Co-60 gamma ray test at AFRL or DTRA-approved facility.

Phase 4 · 36+ months: Operational Infusion Pathways (TRL 7+)

USSF Tetra-5 / On-Orbit Servicing Demonstrations

Align with the four 2026-2028 on-orbit servicing demonstrations: USSF/AFRL Tetra-5 (autonomous RPO + docking + inspection + refueling), Astroscale U.S. Provisioner (GEO hydrazine refueling, USSF SSC), SpaceLogistics MRV (Northrop Grumman, NRL robotic arm, DARPA-funded RSGS), and Astroscale ELSA-M (multi-client servicing/debris removal). Each demonstration requires hardware-enforced authority gating for proximity-operations maneuvers; BLADE-SPACE provides exactly that governance layer.

DARPA Oversight Constellation Custody

Position the MAIVA cross-string Byzantine consensus layer for integration with DARPA Oversight - autonomous constant custody of up to 1,000 targets with operator at aggregate level, not per-target. The BDA stage's post-event trust revalidation provides the "continual assurance" framework that DARPA Assured Autonomy specifies for Learning-Enabled Cyber-Physical Systems. Submit white-paper response to next Oversight BAA opening.

USSF Maneuverable GEO + Race to Resilience

Position as the governance layer for the USSF Maneuverable GEO program (competition opened January 2026) and the broader USSF Race to Resilience initiative (FY2026 Space Force baseline appropriation $26.3B, approaching $40B with reconciliation funding via the "One Big Beautiful Bill Act"). Small / medium maneuverable commercial satellites in GEO require authority-graduated decision-making for autonomous orbit changes - the HMAA + FLAME + CARA stack is positioned for direct integration.

Distributed Constellation Demonstration

Multi-node MAIVA Byzantine consensus across N≥3 BLADE-SPACE governance nodes over inter-satellite optical link (Mynaric CONDOR Mk3); cross-satellite audit-chain hash continuity via ECDSA P-256 chain-of-trust; demonstrate authority-graduated decision-making across a constellation with degraded-node ride-through, swarm continuity under one-node-loss, and cross-satellite health exchange - all four primary capabilities called out in EXPAND.3.S26B.

Honest Risk Disclosure

This roadmap is contingent on funding, partnership, and procurement-pathway availability. Realistic flight-build cost (parts + AI&T NRE + flight qualification) for a 91-component rad-tolerant Class V LEO node is in the $1.5M-$2.5M range, not the $505,440 parts-only reference BOM. ITAR USML Category XV applies to multiple line items and constrains foreign-collaboration pathways. The 12-18 month lead times on Class V rad-hard parts (RTG4, Aitech S-A1760 Venus) drive Phase 2 timing. No NASA, USSF, or DARPA endorsement of BLADE-SPACE is claimed or implied; programs cited are real and current as of May 2026 and represent targeted submission vehicles, not awarded contracts.

Proposed SDK interface (not implemented)

No SDK package has been published; the code below illustrates a proposed interface. The proposed BLADE Governance SDK would provide a unified API across the BLADE platform family, with a single blade_governance library covering defense weapons governance (BLADE-EDGE), autonomous vehicle authority (BLADE-AV), maritime surveillance (BLADE-MARITIME), critical infrastructure protection (BLADE-INFRA), orbital autonomy (BLADE-SPACE), and counter-UAS authority (BLADE-CUAS); only the domain configuration file would change.

blade_space.yaml Orbital (Space-Edge)
domain: orbital
pipeline: SATA → ADARA → IFF → HMAA → MAIVA → FLAME → CARA → BDA → EFFECTOR

sensors:
 - id: star_tracker
 type: blue_canyon_nst100
 weight: 0.35
 cross_validate: [gnss, imu_tactical]
 - id: gnss
 type: novatel_oem7600_rg
 weight: 0.25
 cross_validate: [star_tracker, imu_tactical]
 - id: imu_tactical
 type: sensonor_stim_300
 weight: 0.25
 cross_validate: [star_tracker, gnss]
 - id: sun_sensor
 type: adcole_digital_array
 weight: 0.15
 cross_validate: [star_tracker]

effector:
 type: thruster_firing + magnetorquer + reaction_wheel
 relay: normally_open_interlock_x2_series
 safety_standard: NASA_STD_5017 + NASA_STD_8719_27
 authority_gate: HMAA_authority + safe_arm_plug
 fail_safe: sun_pointing_safe_mode

authority:
 A3_threshold: 0.85 # Propulsive maneuver authorized
 A2_threshold: 0.60 # Reaction wheel only, no thruster
 A1_threshold: 0.35 # Attitude hold, no maneuvers
 A0_action: safe_mode # NO relays open, payload off
 hysteresis_up_s: 30 # Long climb (eclipse-aware)
 hysteresis_down_s: 0 # Immediate downgrade
integration_example.py Python
import blade_governance as bg

# Initialize with orbital domain config
pipeline = bg.GovernancePipeline("blade_space.yaml")

# In your spacecraft ACS/payload control loop (10Hz):
while mission_active:
 sensors = get_sensor_readings() # ST, GNSS, IMU, sun

 result = pipeline.evaluate(sensors)
 # result.trust → 0.91
 # result.authority → "A3"
 # result.deception_p → 0.02
 # result.flame_hold_ms → 5000 # deliberation
 # result.execute → True

 if result.execute and result.authority == "A3":
 thruster.fire(result.envelope) # gated through 2× NO relays
 elif result.authority == "A0":
 pipeline.cara_recover() # sun-pointing safe-mode
ROS 2 Topic Map
# ROS 2 Topic Map, Orbital
/blade/sata/fused_trust # Float64 τ ∈ [0,1]
/blade/hmaa/authority_level # UInt8 {A3,A2,A1,A0}
/blade/hmaa/maneuver_envelope # ManeuverMsg
/blade/flame/circuit_breaker # UInt8 state
/blade/flame/deliberation_ms # UInt32 hold time
/blade/cara/grep_phase # String {GUARD,REDUCE,EVALUATE,PROMOTE}
/blade/effector/thruster_interlock # Bool (NO relay × 2 state)
/blade/adara/gnss_spoof_prob # Float64 P(spoofing)
/blade/bda/orbit_revalidation # OrbitRevalidation
Unified API Surface SAME ACROSS ALL PLATFORM FAMILY
# Core API, domain-agnostic
pipeline = bg.GovernancePipeline(config)
result = pipeline.evaluate(sensors)
recovery = pipeline.cara_recover()

# result object, universal fields
result.trust # Float64 τ ∈ [0,1]
result.authority # String {A3,A2,A1,A0}
result.deception_p # Float64 P(adversarial)
result.flame_hold_ms # UInt32 deliberation window
result.execute # Bool action permitted
result.relay_state # Bool hardware interlock
result.grep_phase # String CARA state

# Lifecycle
pipeline.get_audit_chain() # Hash-chained log
pipeline.export_forensics() # BLADE-BLACKBOX
pipeline.get_config() # Current domain cfg

Cross-Domain Portability: The proposed blade_governance SDK would use the same evaluate() → result API across every platform in the family. Switching from orbital governance (BLADE-SPACE) to defense weapons authority (BLADE-EDGE) or any of the five would require changing only the YAML configuration file, not the application code.

About This Project

The BLADE-SPACE Governance Node is part of the independent authority-governed autonomy research program by Burak Oktenli.

Related research architectures: SATA (sensor trust), HMAA (authority computation), CARA (recovery), MAIVA (multi-agent trust), FLAME (latency control), ADARA (deception-aware risk).

Companion BLADE reference designs (not built): BLADE-EDGE (defense), BLADE-AV (automotive), BLADE-MARITIME (maritime), BLADE-INFRA (critical infrastructure). BLADE-SPACE (orbital) is the fifth domain instantiation of the AUTHREX governance stack.

View full research portfolio →